Rl Rvo Nav AI Agent
 by hanruihua
[RA-Letter 2022] Reinforcement Learned Distributed Multi-Robot Navigation with Reciprocal Velocity Obstacle Shaped Rewards
Rl Rvo Nav is an open-source ai agent by hanruihua, written mainly in Python, with 298 GitHub stars and the MIT license. Its code was last updated Oct 21, 2026.
rl_rvo_nav
Introduction
This repository is the source code of the paper "Reinforcement Learned Distributed Multi-Robot Navigation with Reciprocal Velocity Obstacle Shaped Rewards" [RA-Letter]
PDF_ieee | PDF_arxiv | Video_Youtube | Video_Bilibili
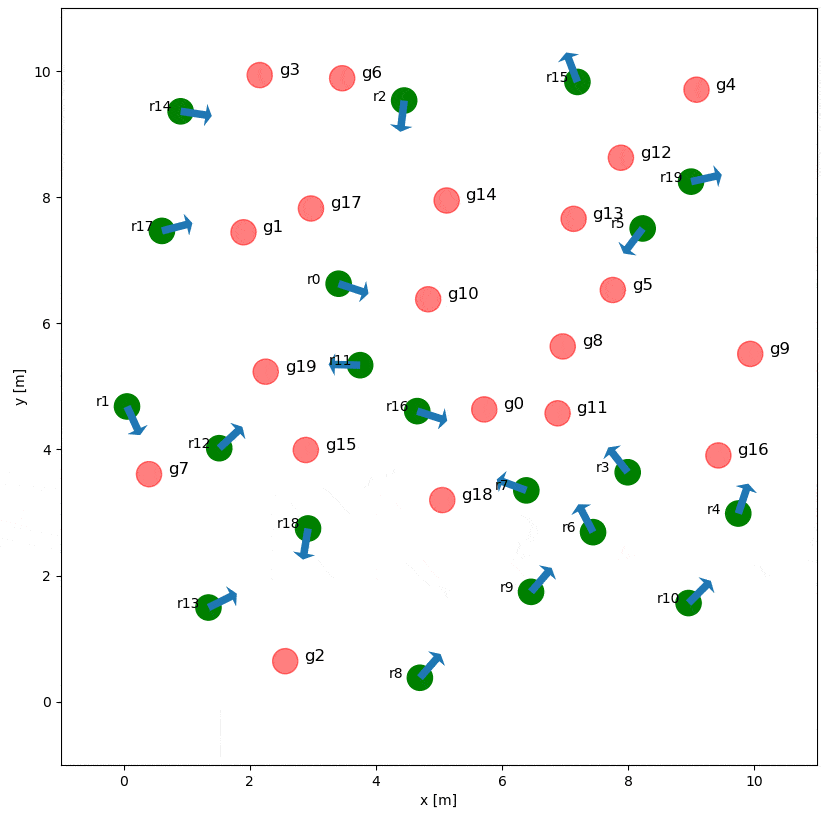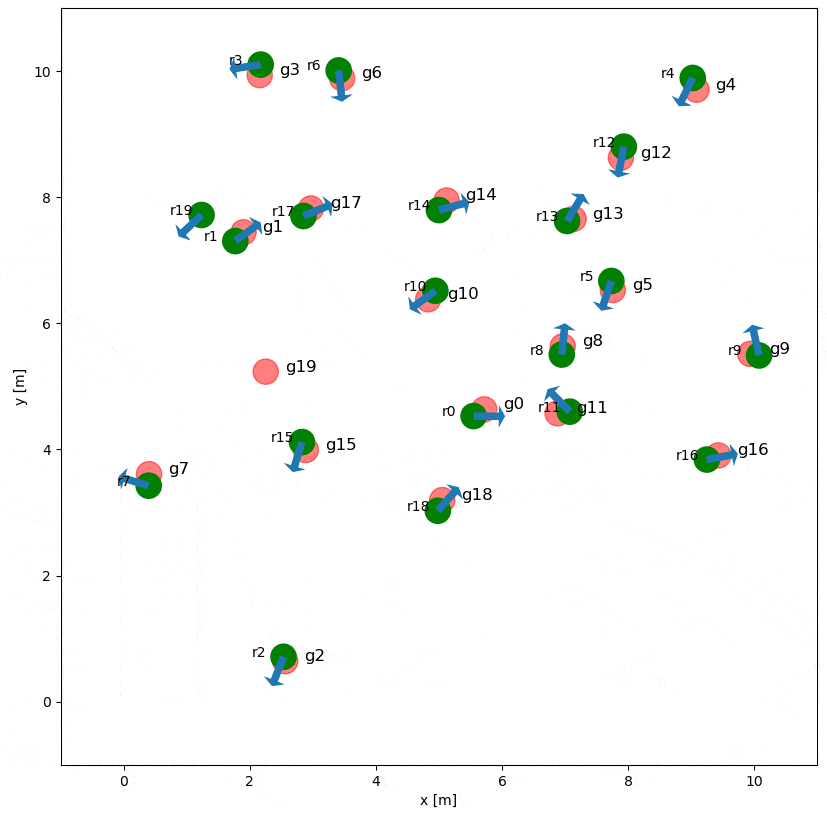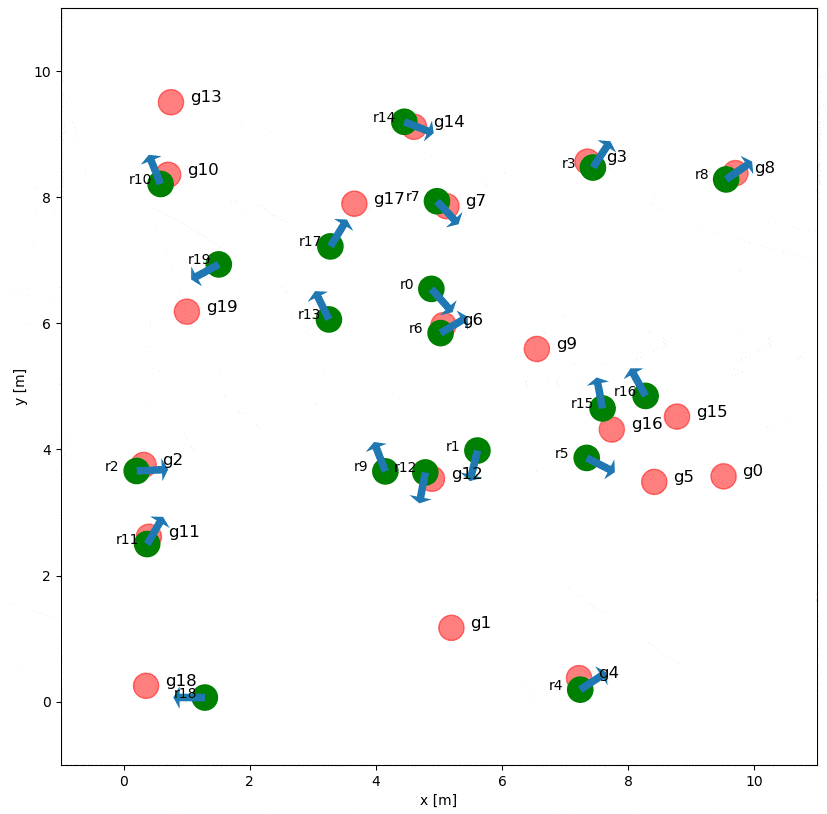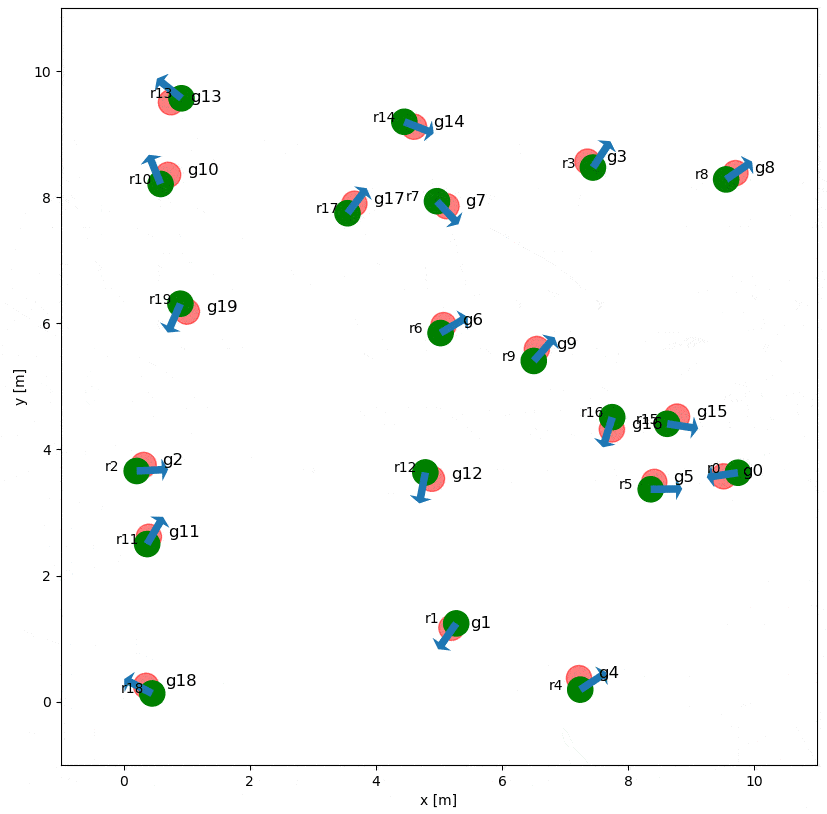
| Circle 10 | Circle 16 | Circle 20 |
|---|---|---|
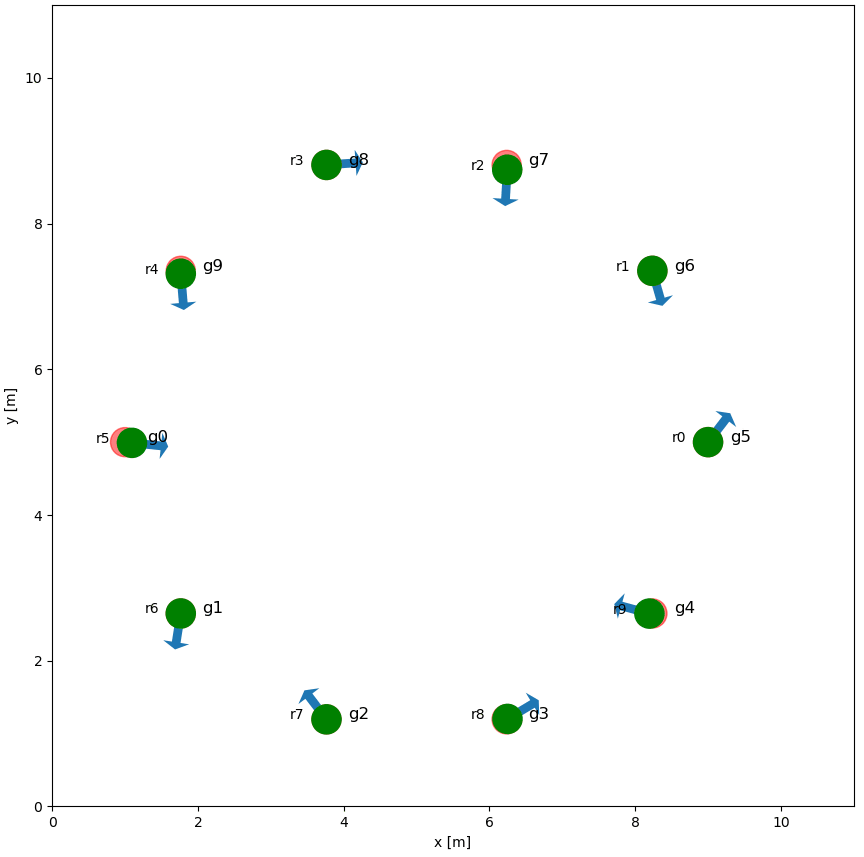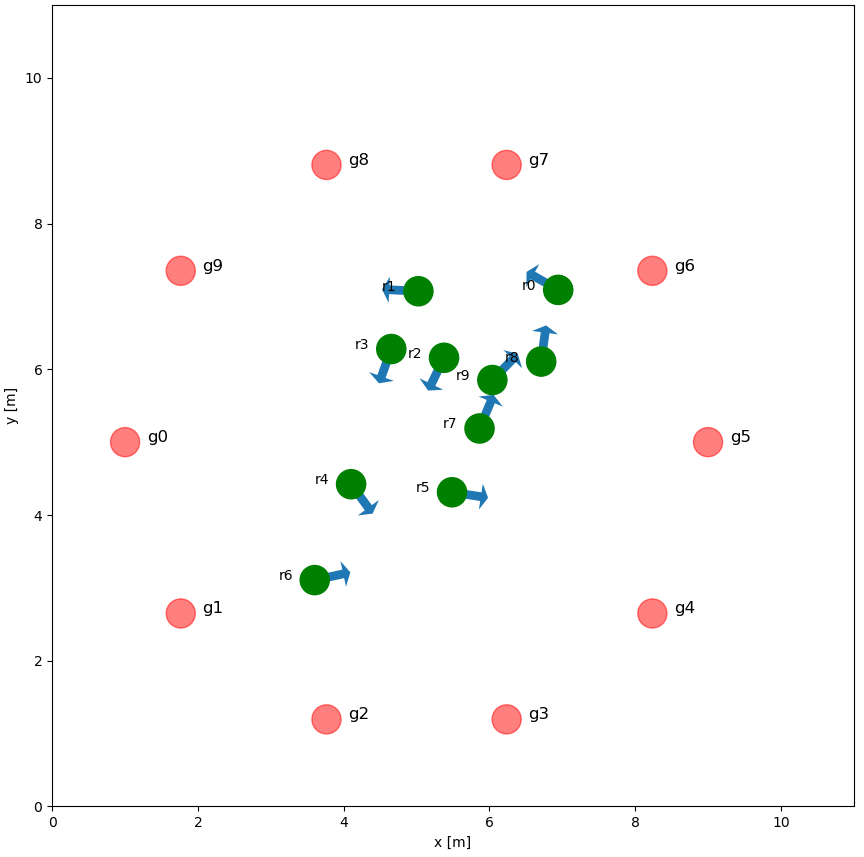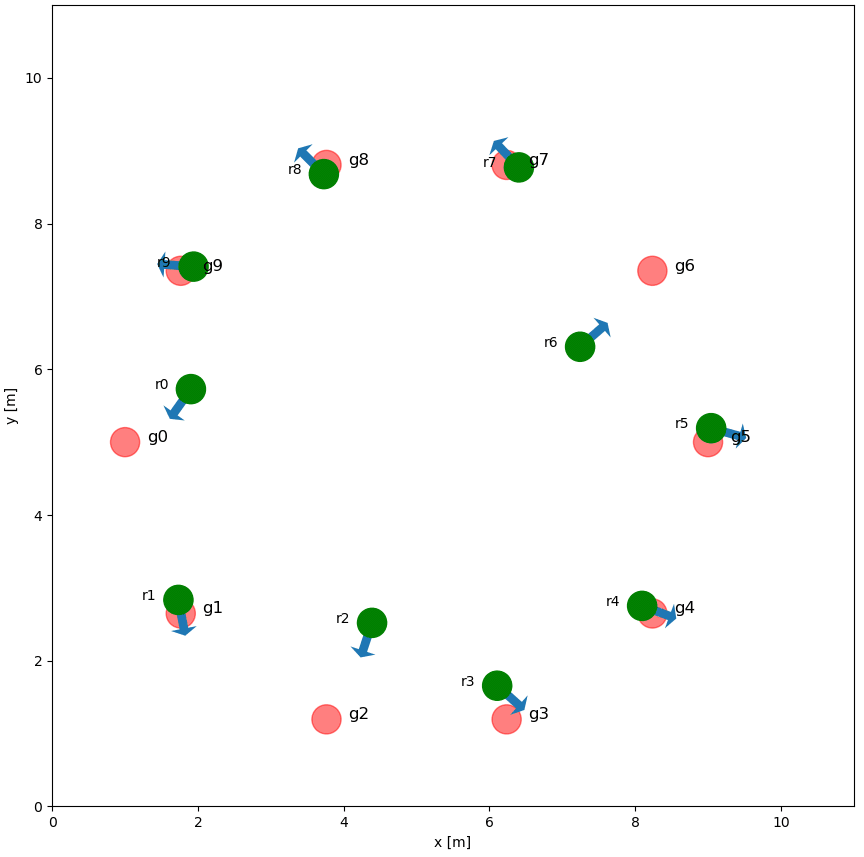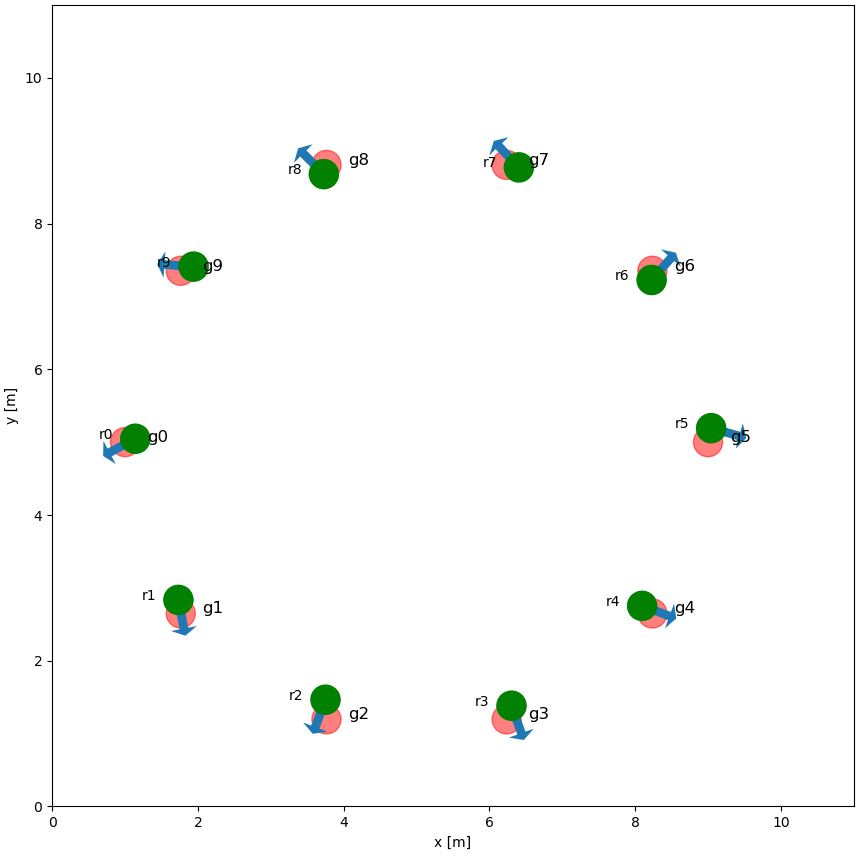 | 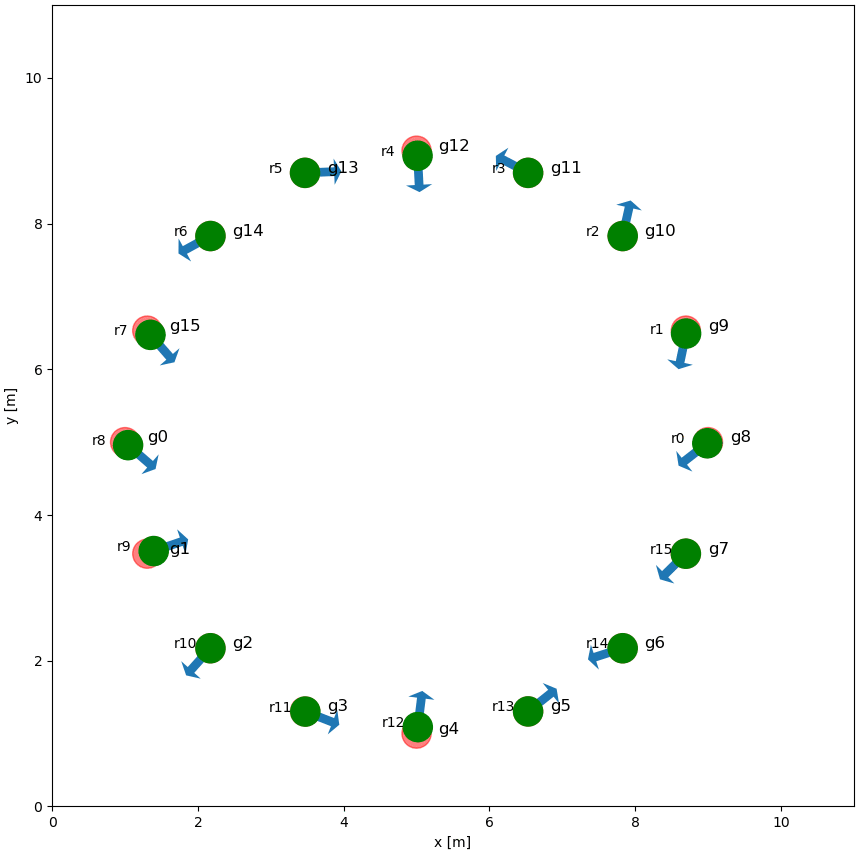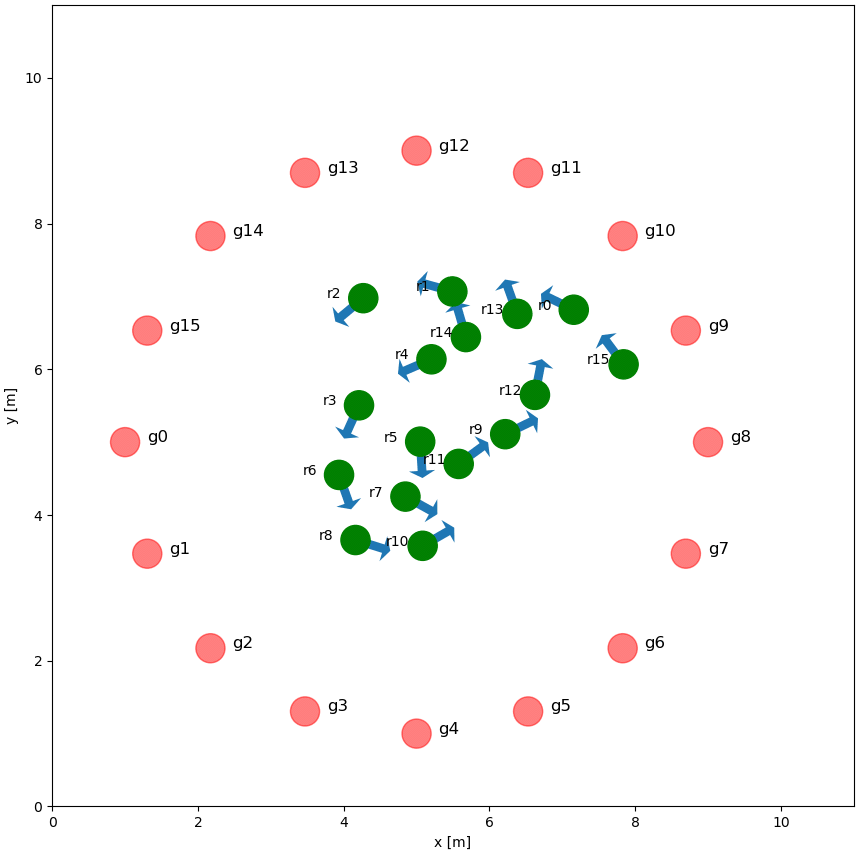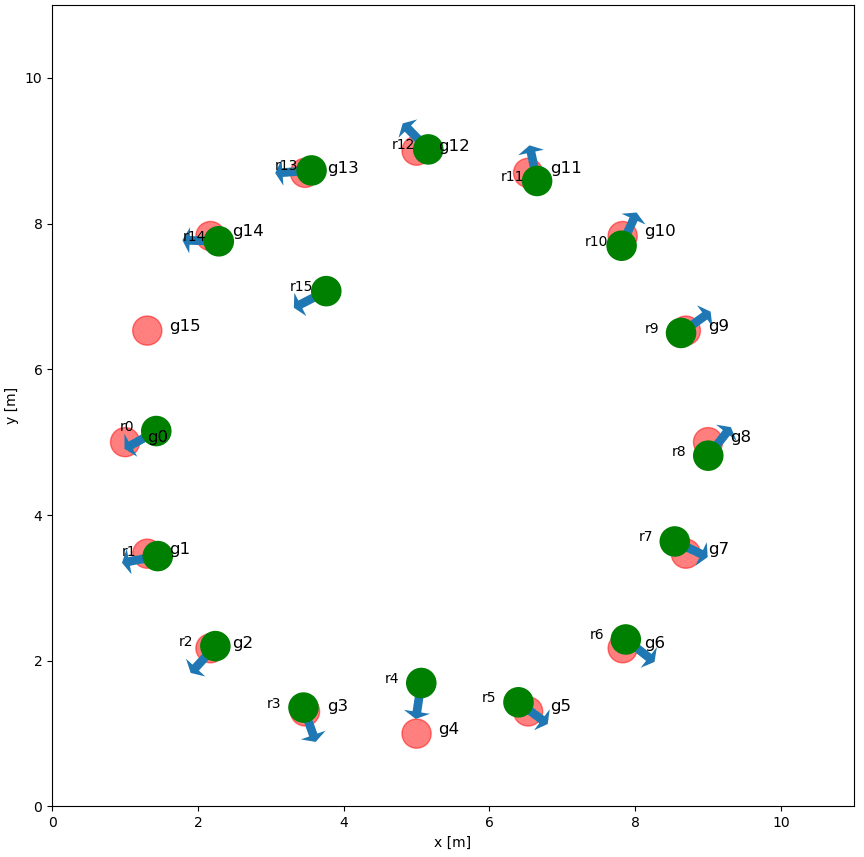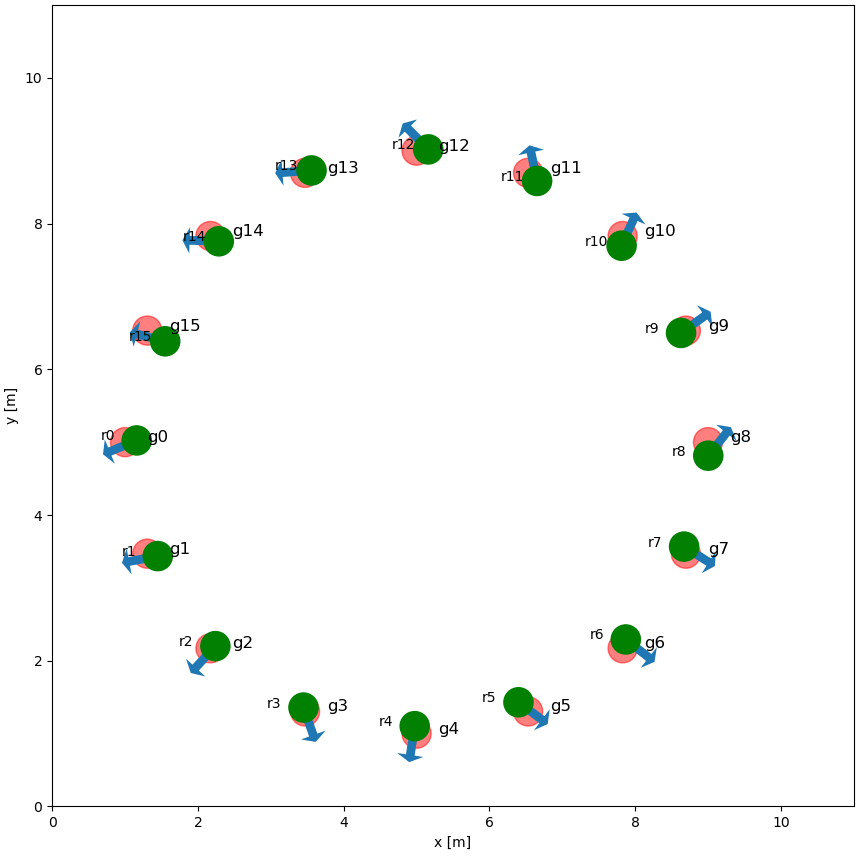 | 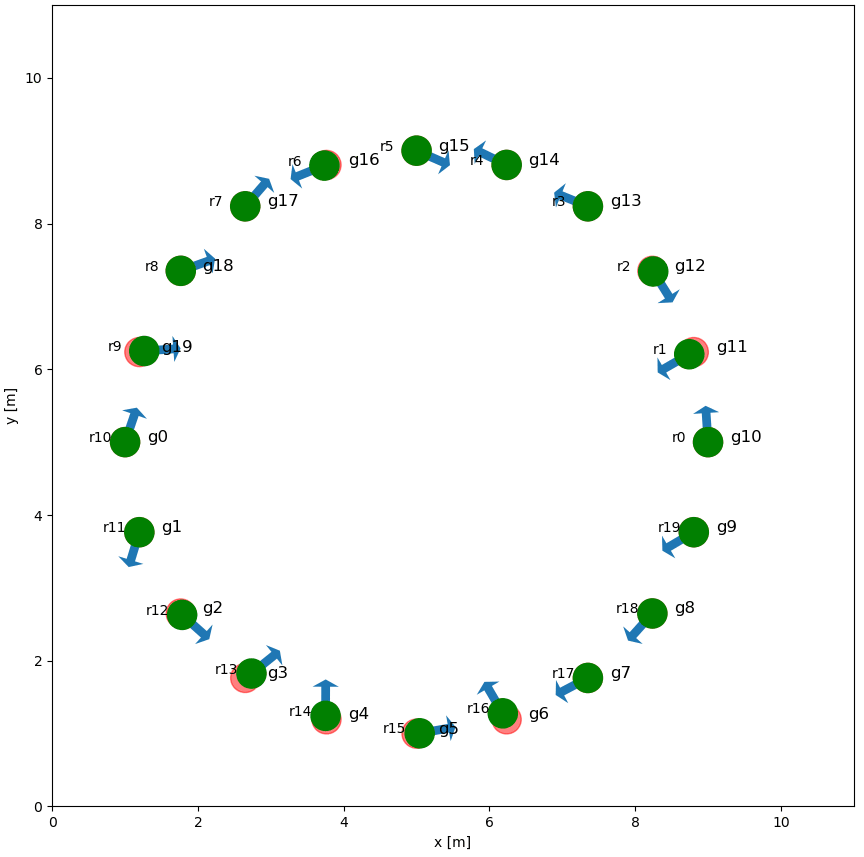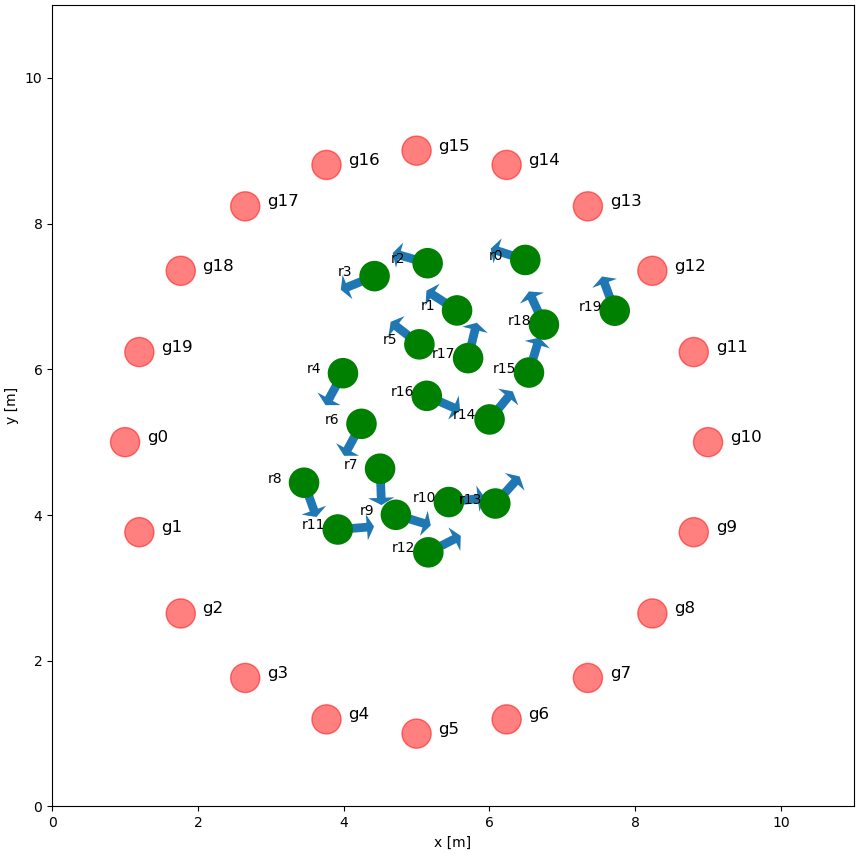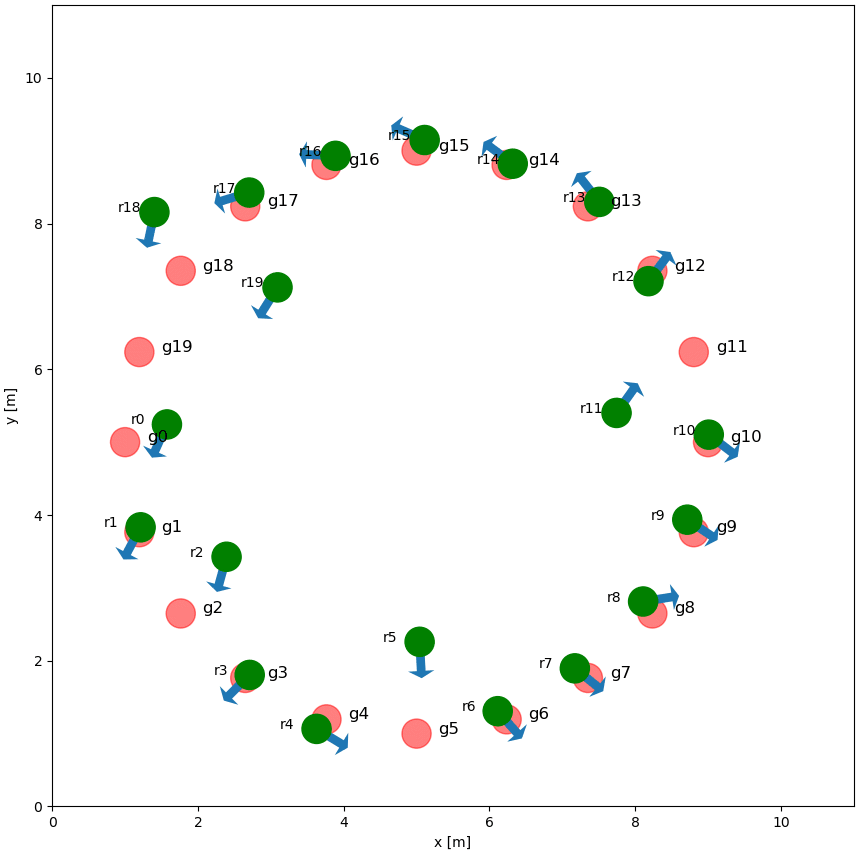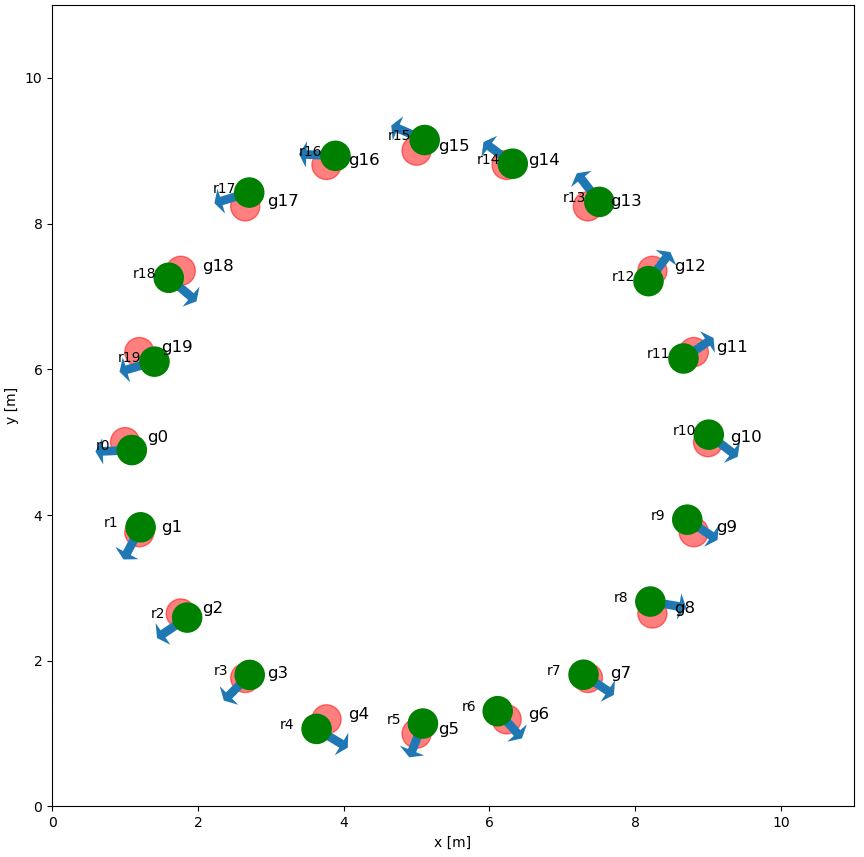 |
| Random 10 | Random 16 | Circle 20 |
|---|---|---|
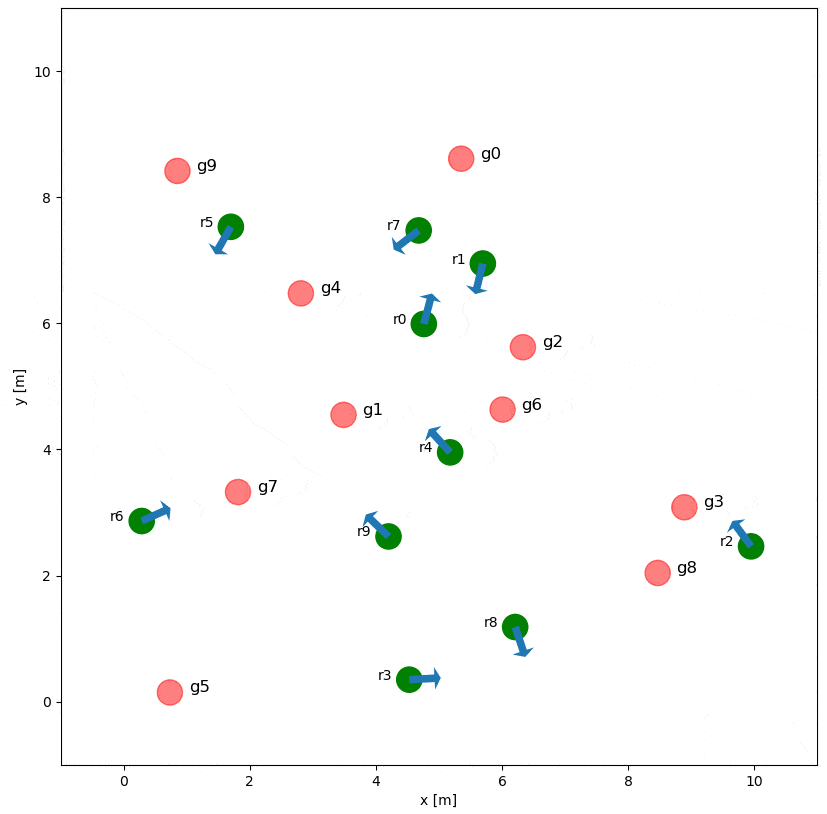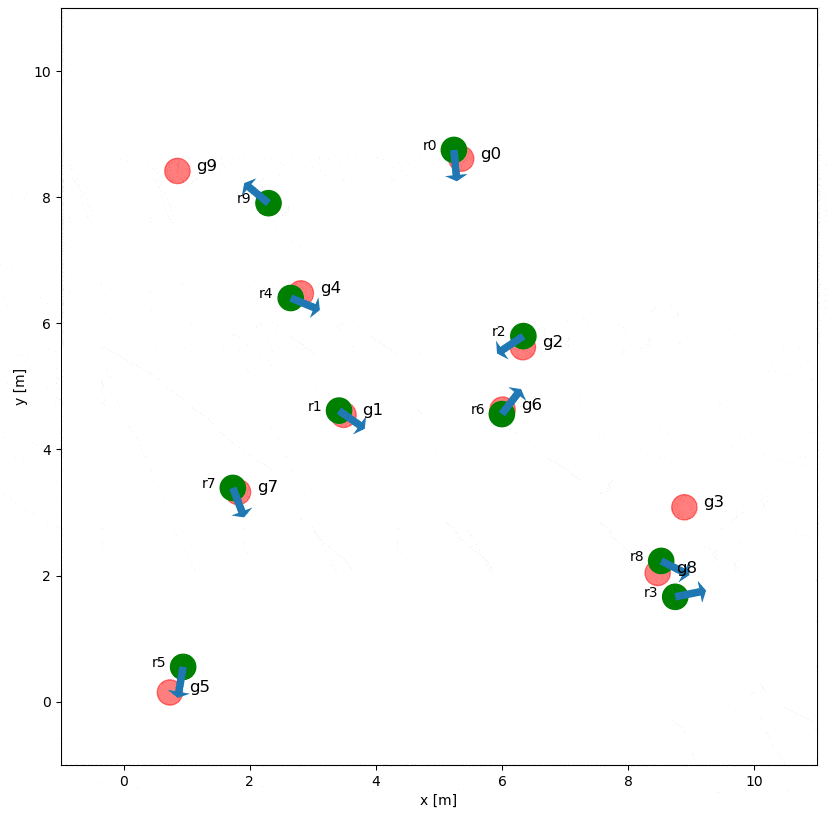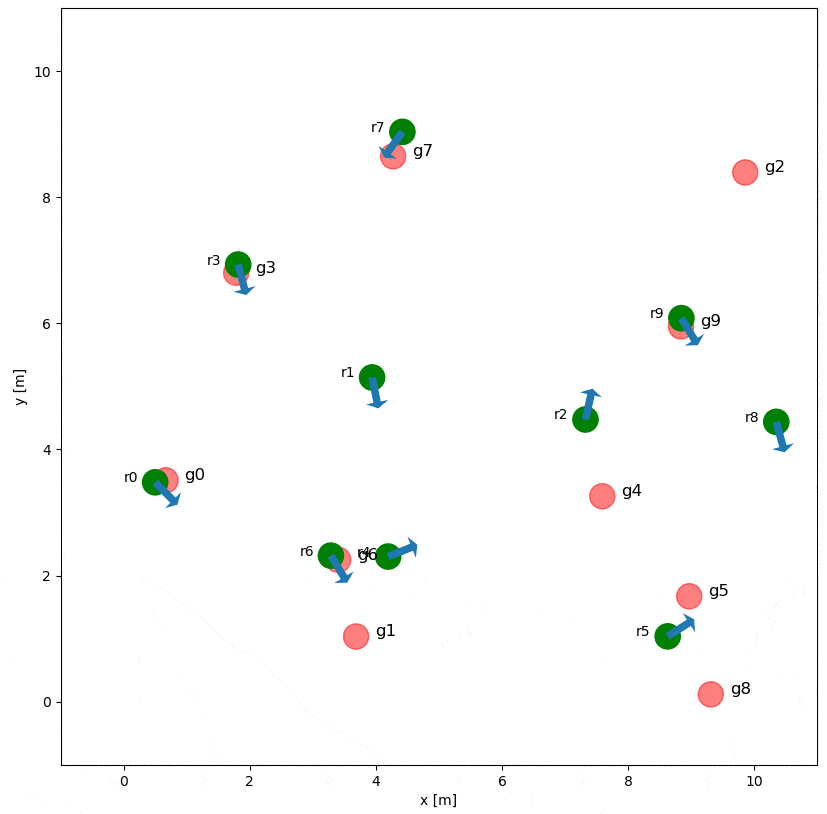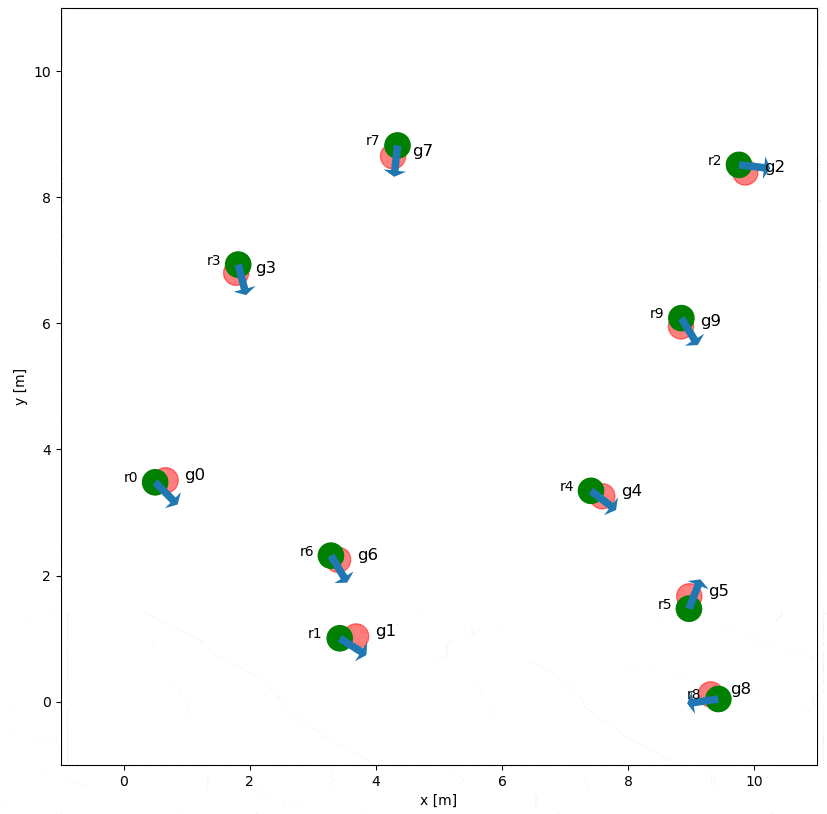 | 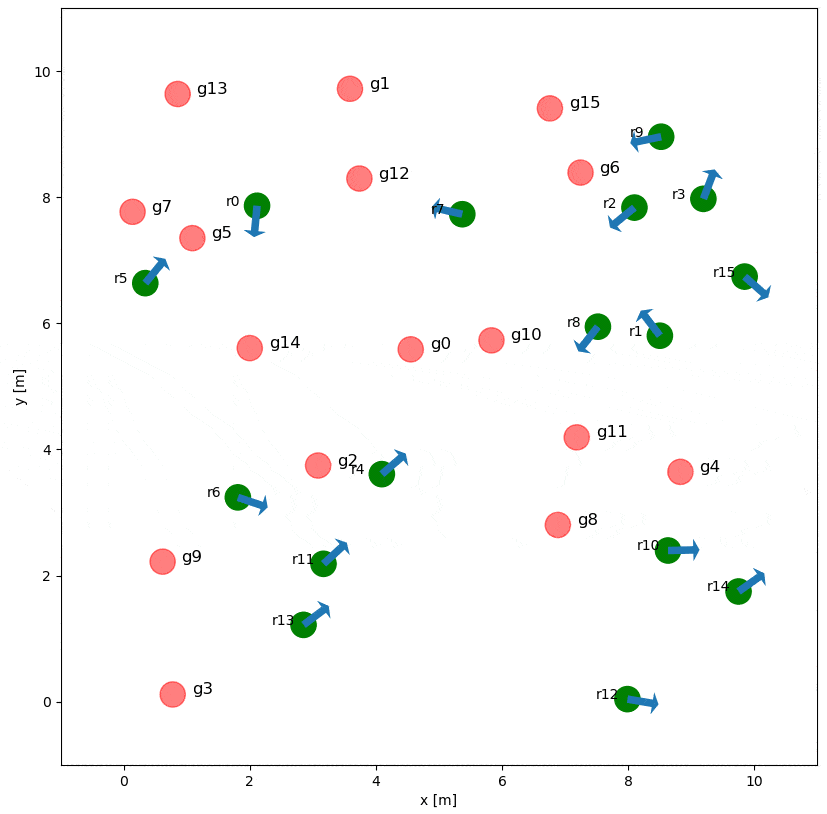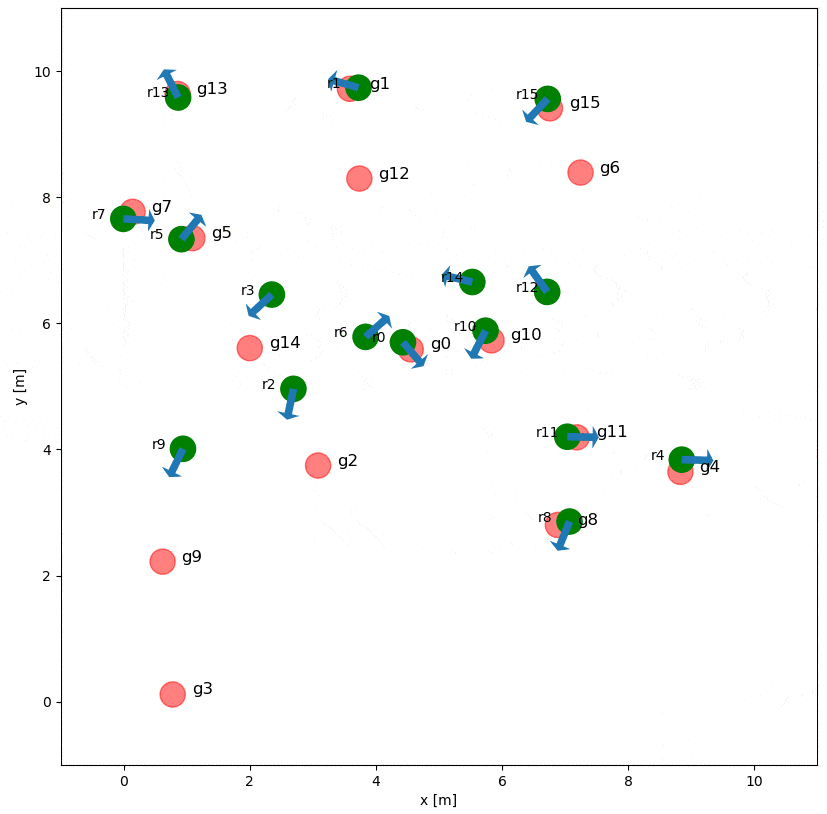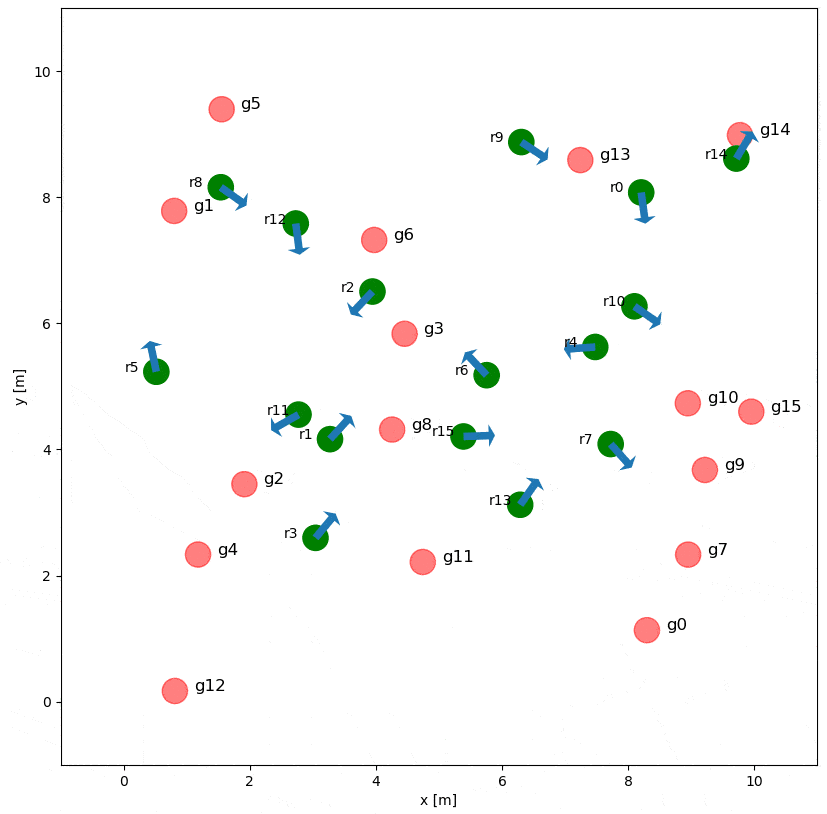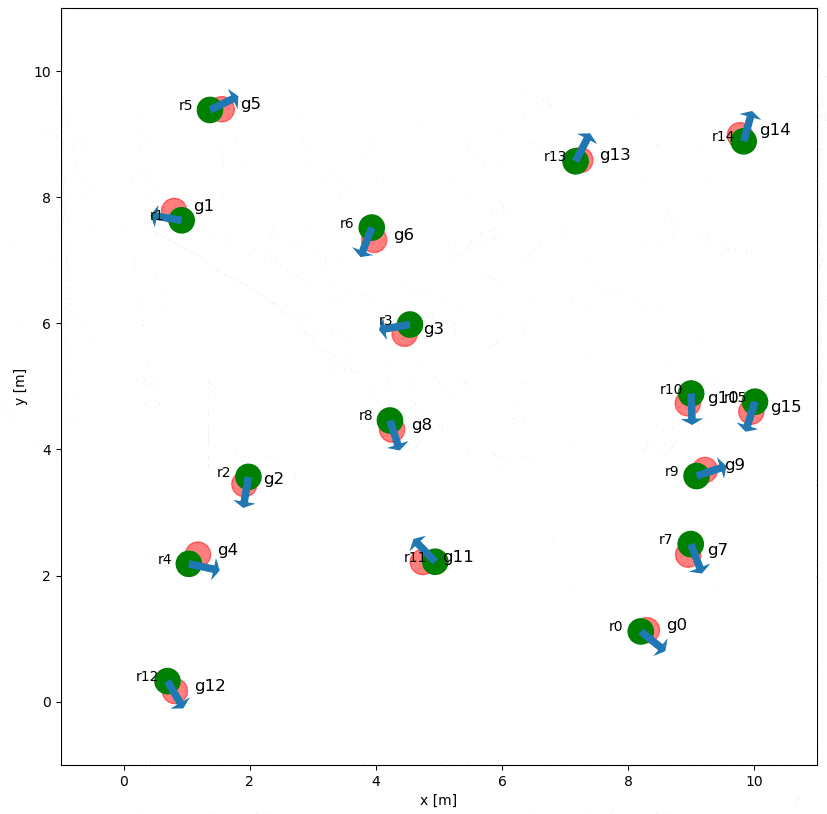 |  |
Prerequisites
- Python >= 3.8
- Pytorch >= 1.6.0
- intelligent-robot-simulator == v2.5
git clone -b v2.5 https://github.com/hanruihua/intelligent-robot-simulator.git
cd intelligent-robot-simulator
pip install -e .
Test environment
- Ubuntu 20.04, 18.04
- Windows 10, 11
Installation
git clone https://github.com/hanruihua/rl_rvo_nav.git
cd rl_rvo_nav
./setup.sh
Policy Train
- First stage: circle scenario with 4 robots.
python train_process.py --use_gpu
or
python train_process_s1.py
- Second stage: continue to train in circle scenario with 10 robots.
python train_process.py --robot_number 10 --train_epoch 2000 --load_name YOUR_MODEL_PATH --use_gpu --con_train
or
python train_process_s2.py
Policy Test
You can test the policy trained from the previous steps by following command:
python policy_test.py --robot_number 10 --dis_mode 3 --model_name YOUR_MODEL_NAME --render
Note1: dis_mode, 3, circle scenario; 2 random scenario
Note2: YOUR_MODEL_NAME refer to the path and name of the check point file in the policy_train/model_save folder
Pretrained model
We provide the pre_trained model, you can test this model by following command:
python policy_test_pre_train.py --render
Citation
If you find this code or paper helpful, please consider starring this repository and citing our paper:
@article{han2022reinforcement,
  title={Reinforcement Learned Distributed Multi-Robot Navigation With Reciprocal Velocity Obstacle Shaped Rewards},
  author={Han, Ruihua and Chen, Shengduo and Wang, Shuaijun and Zhang, Zeqing and Gao, Rui and Hao, Qi and Pan, Jia},
  journal={IEEE Robotics and Automation Letters},
  volume={7},
  number={3},
  pages={5896--5903},
  year={2022},
  publisher={IEEE}
}
This project uses IR-SIM. If you use the simulator in your work, please also cite:
@article{han2026ir,
  title={IR-SIM: A Lightweight Declarative Simulator for Navigation Learning and Benchmarking},
  author={Han, Ruihua and Wang, Shuai and Li, Chengyang and Gao, Rui and Wang, Xinyi and Liu, Zhe and Li, Guoliang and Lu, Yupu and Hao, Qi and Pan, Jia and Zhao, Hengshuang},
  journal={arXiv preprint arXiv:2606.08729},
  year={2026},
  doi={10.48550/arXiv.2606.08729},
  url={https://arxiv.org/abs/2606.08729},
  eprint={2606.08729},
  archivePrefix={arXiv},
  primaryClass={cs.RO}
}
Author
Han Ruihua
Contact: hanrh@connect.hku.hk
Rl Rvo Nav alternatives
View more →Similar ai agents in Learning Resources, ranked by GitHub stars. Compare licence, recent activity and scan status before you choose.
| Name | Stars | Licence | Last updated | Scan |
|---|---|---|---|---|
| Rl Rvo Nav (this page) hanruihua | 298 | MIT | Oct 21, 2026 | Scanned, no flagged issues |
| Prompt Engineering Guide dair-ai | 80k | MIT | Mar 11, 2026 | Scanned, no flagged issues |
| Learn Claude Code shareAI-lab | 80k | MIT | Oct 27, 2026 | Scanned, no flagged issues |
| AI Engineering From Scratch rohitg00 | 76k | MIT | Oct 29, 2026 | Scanned, no flagged issues |
| Front End Checklist thedaviddias | 75k | MIT | Oct 31, 2026 | Scanned, no flagged issues |
| System Prompts Leaks asgeirtj | 71k | CC0-1.0 | Nov 1, 2026 | Scanned, no flagged issues |